PrototypingMember portfolio
Robotic hand
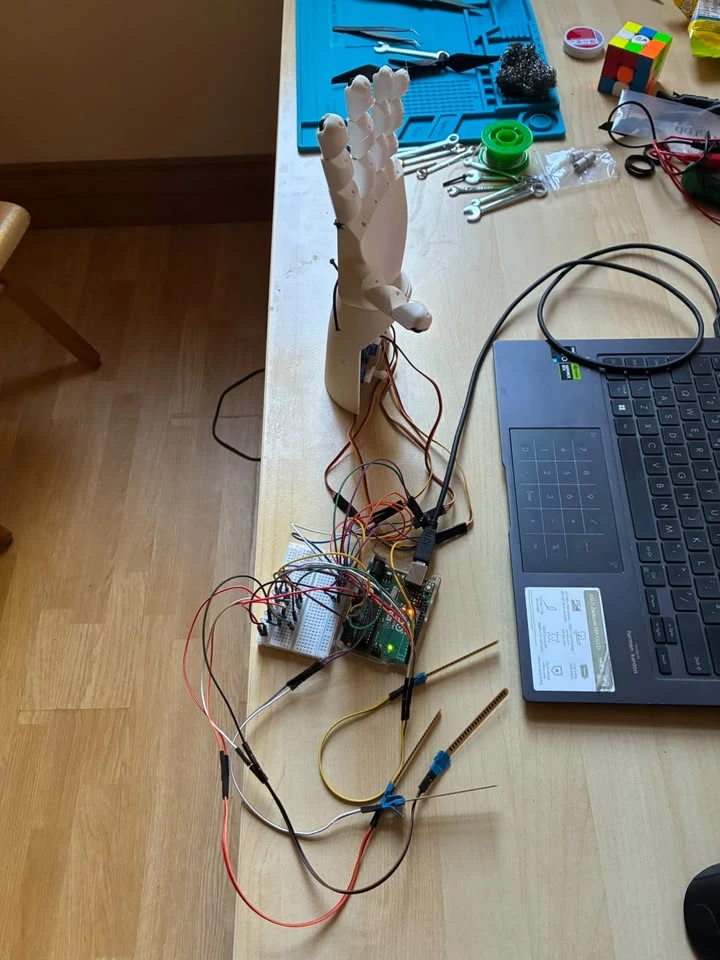
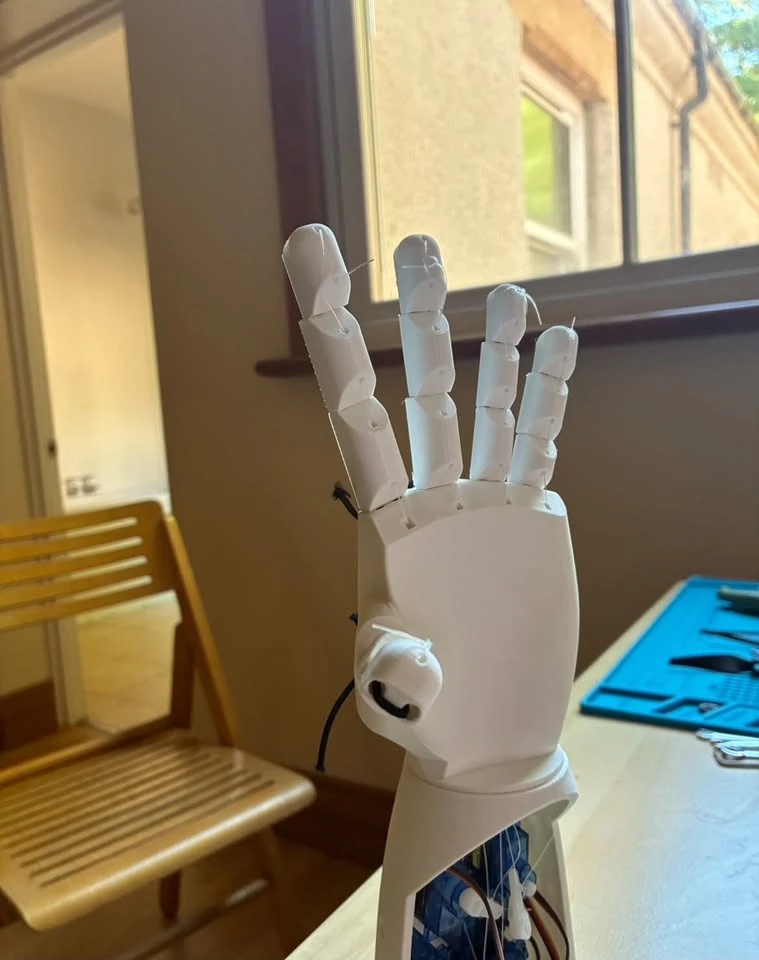
A printed robotic hand controlled by a flex-sensor glove.
The brief
Translate finger movement into motion in a physical robotic hand.
The approach
Arduino reads flex-sensor voltages and maps them to servo angles. Servos pull tendons to curl the printed fingers.
Work shown
- Printed hand assembly
- Sensor and servo integration
- Arduino control mapping